RoboMeasure Project - Turning a Robotic Gripper into a Sensor
Can a robot measure an object just by grasping it?
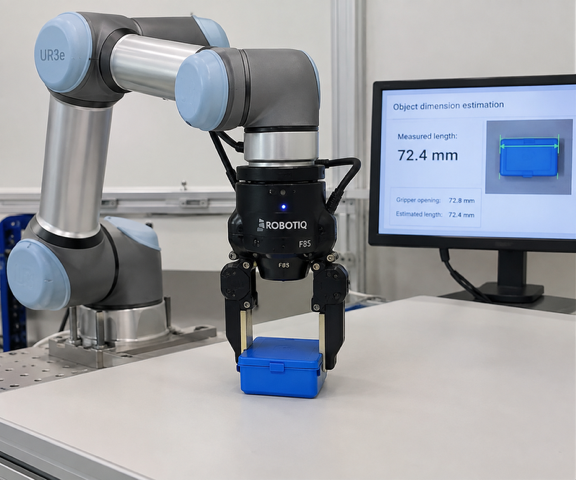
A robotic gripper usually does just one thing: it grips. In the RoboMeasure project at the School of Engineering and Management of the University of Nova Gorica, we aim to turn it into a measuring instrument. Instead of relying on cameras, laser scanners or other external sensors, the robot will gather information about an object through direct physical contact. In modern robotics, this approach is known as active sensing.
Using a Universal Robots UR3e industrial collaborative robot and a Robotiq 2F-85 gripper, the project team will develop a method for estimating the dimensions of sample objects. The method will be based on the gripper opening, the position of the fingers and the contact point, the gripping force and the motion of the gripper. The team will analyse the measurements in Python and Jupyter Notebooks, compare them with reference measurements taken with a caliper, and determine the measurement error and measurement uncertainty in accordance with metrology standards. The measuring station will be designed and visualised in SolidWorks and RoboDK.
The project will run from December 2026 to June 2027. The results will be presented in a technical report and may serve as the basis for a conference paper, for example at the IEEE ERK conference or within the ACROSS European University Alliance.