Participating in the RoboMeasure Project
Can a robot measure an object just by touching it?
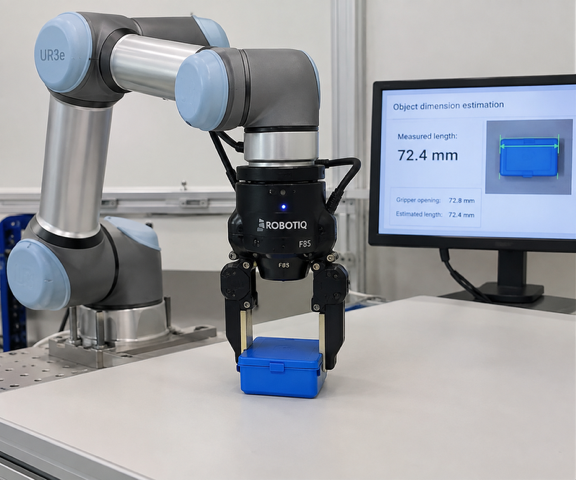
Cameras and laser scanners are old news. In the RoboMeasure project, we will turn a robotic gripper into a measuring instrument: the robot will determine an object’s dimensions simply by grasping it. To do this, it will take into account the gripper opening, finger position, force and motion. This is called active sensing, and it is one of the hot topics in modern robotics.
What will you do?
You will work with a real industrial collaborative robot, the Universal Robots UR3e, and a Robotiq 2F-85 gripper. You will program the robot, design the measuring station in SolidWorks and RoboDK, analyse the data in Python and Jupyter Notebooks, compare the results with caliper measurements, and find out how accurately the robot really measures.
Why is it worth it?
- hands-on experience with equipment used in industry,
- the opportunity to publish and present your work at a conference, e.g. IEEE ERK or within the ACROSS European University Alliance,
- a PTF certificate upon completion,
- all costs, including travel and meals, covered by UNG.